Kepler Nav Company - Leadership, Team, and Deep Space Navigation Mission
Structured for autonomous deep-space mission execution.
Kepler Nav operates under a unified command hierarchy - anchored by Executive Command at Level 1 and 8 specialized Division Leads at Level 2.
Chief Executive & Technical Director
Sanjay S
"Primary researcher behind IEEE Observability Proof, inventor of UNIF-PNT Lie Group manifold navigation, and Founder of Kepler Nav."
8 Specialized Engineering Division Leads
Data Intelligence Division
"Engineering ultra-low latency real-time telemetry processing pipelines and cislunar trajectory data ingestion systems."
Navigational AI Division
"Developing non-linear Lie algebra state estimation filters and autonomous star tracker optical algorithms."
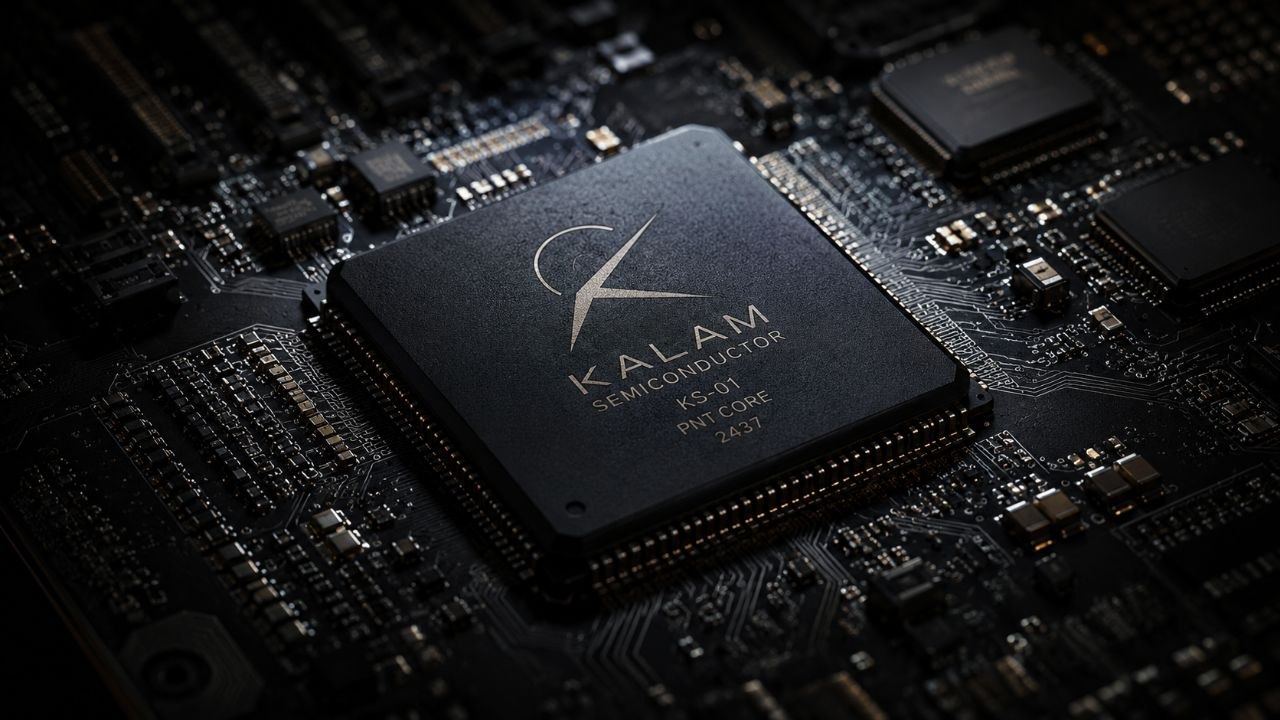
Embedded Systems & Silicon Hardware
"Designing Kalam-class FPGA netlist acceleration silicon, high-frequency PCB substrate routing, and space-hardened microcontrollers."
Branding & Storytelling Division
"Crafting world-class aerospace visual identity, technical publications, documentary storytelling, and international defense media."
AI Mission Simulation Division
"Building high-fidelity Hardware-in-the-Loop (HWIL) orbital flight simulators and synthetic pulsar constellation testbeds."
Research & Development Division
"Pioneering fundamental Lie algebra observability proofs, deep-space autonomous navigation theory, and state recovery validation."
Cyber Defense & Communications
"Hardening deep-space RF links against jamming, spoofing, and signal degradation using quantum-resistant encryption."
Finance & Strategic Capital Division
"Directing capital strategy, international defense venture partnerships, fiscal governance, and scaling deep-tech aerospace infrastructure."
Join the mission to redefine autonomous navigation.
We are actively expanding our divisions for FPGA silicon engineers, Lie algebra mathematicians, and embedded Rust developer fellows.
Deep-space PNT architecture, answered.
Explore technical specifications covering deep-space autonomous navigation, X-ray pulsar timing (XNAV), Kalam FPGA silicon, Lie Group manifold observability, and electronic warfare immunity.
Kepler Nav combines photonic star tracking, X-ray pulsar timing (XNAV), and Lie Group manifold state estimation (Theorem 1.2). By measuring ambient pulsar X-ray phase arrival times and optical star vectors, the system computes 6-DOF autonomous orbit states anywhere from LEO to Cislunar and interplanetary Mars transfer trajectories with zero ground station reliance.
Have specific deep-space orbital vectors or simulation requirements?
Our R&D team provides customized Lie Group manifold simulation models, XNAV pulsar ephemeris datasets, and hardware-in-the-loop netlist integration.
Build with Kepler Nav.
Partner with our engineering team to integrate the UNIF-PNT navigation engine or deploy Kalam-Zero payloads for satellite and defense platforms.